CoBiz-based Integrated GPS and Robot Monitoring with Anomaly Verification System
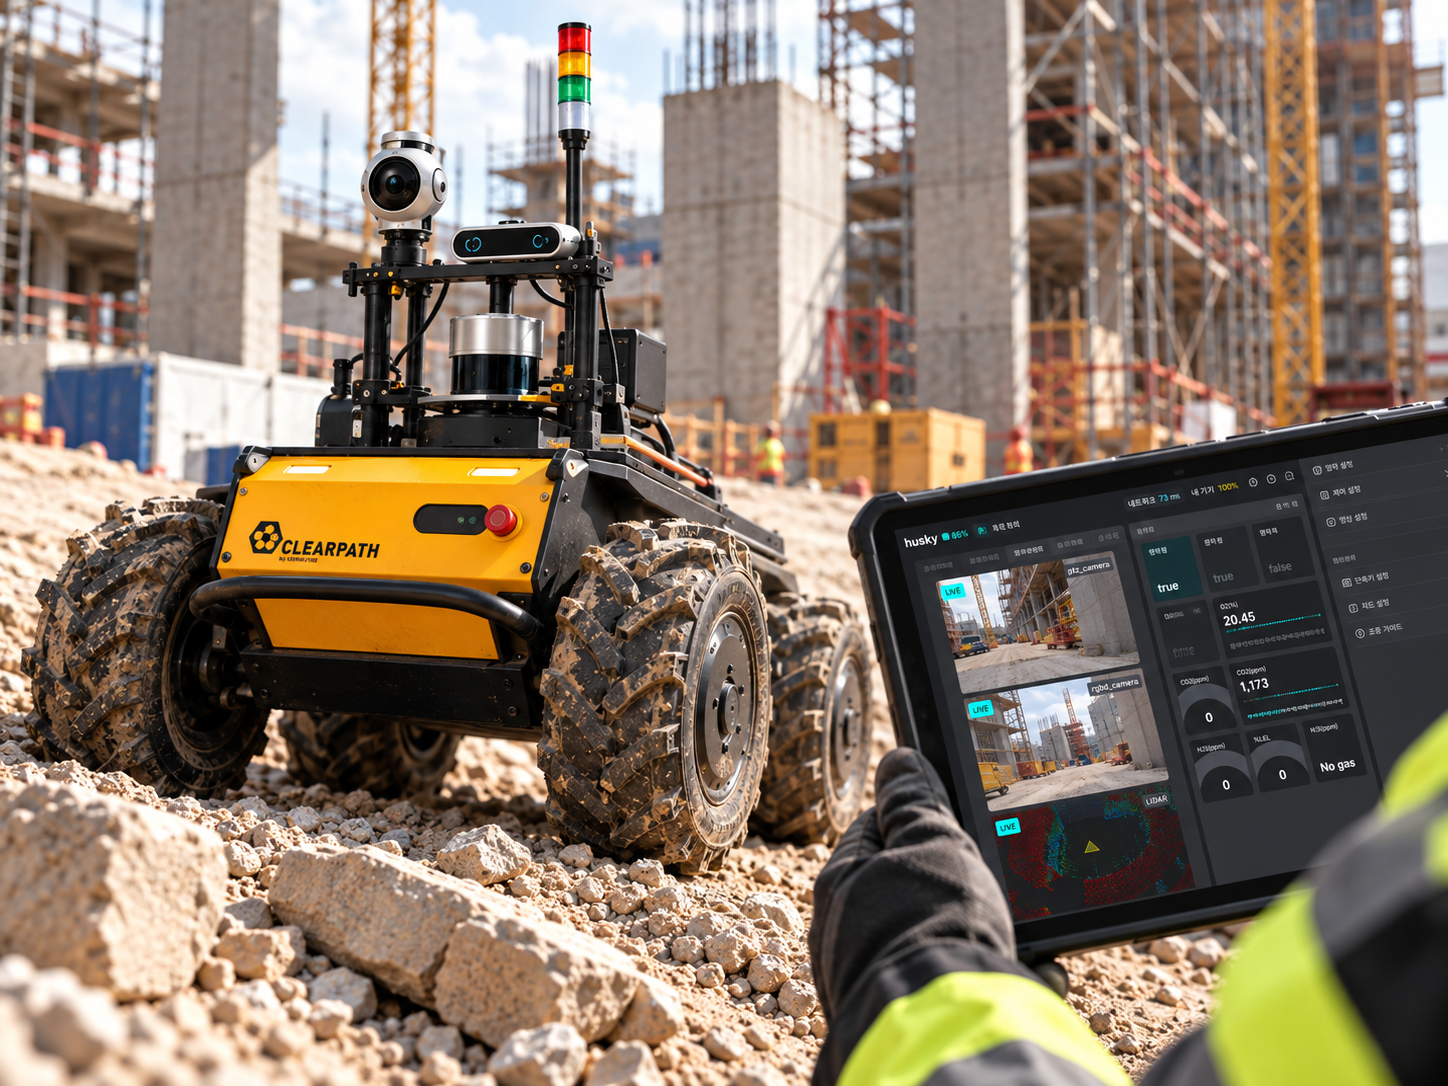
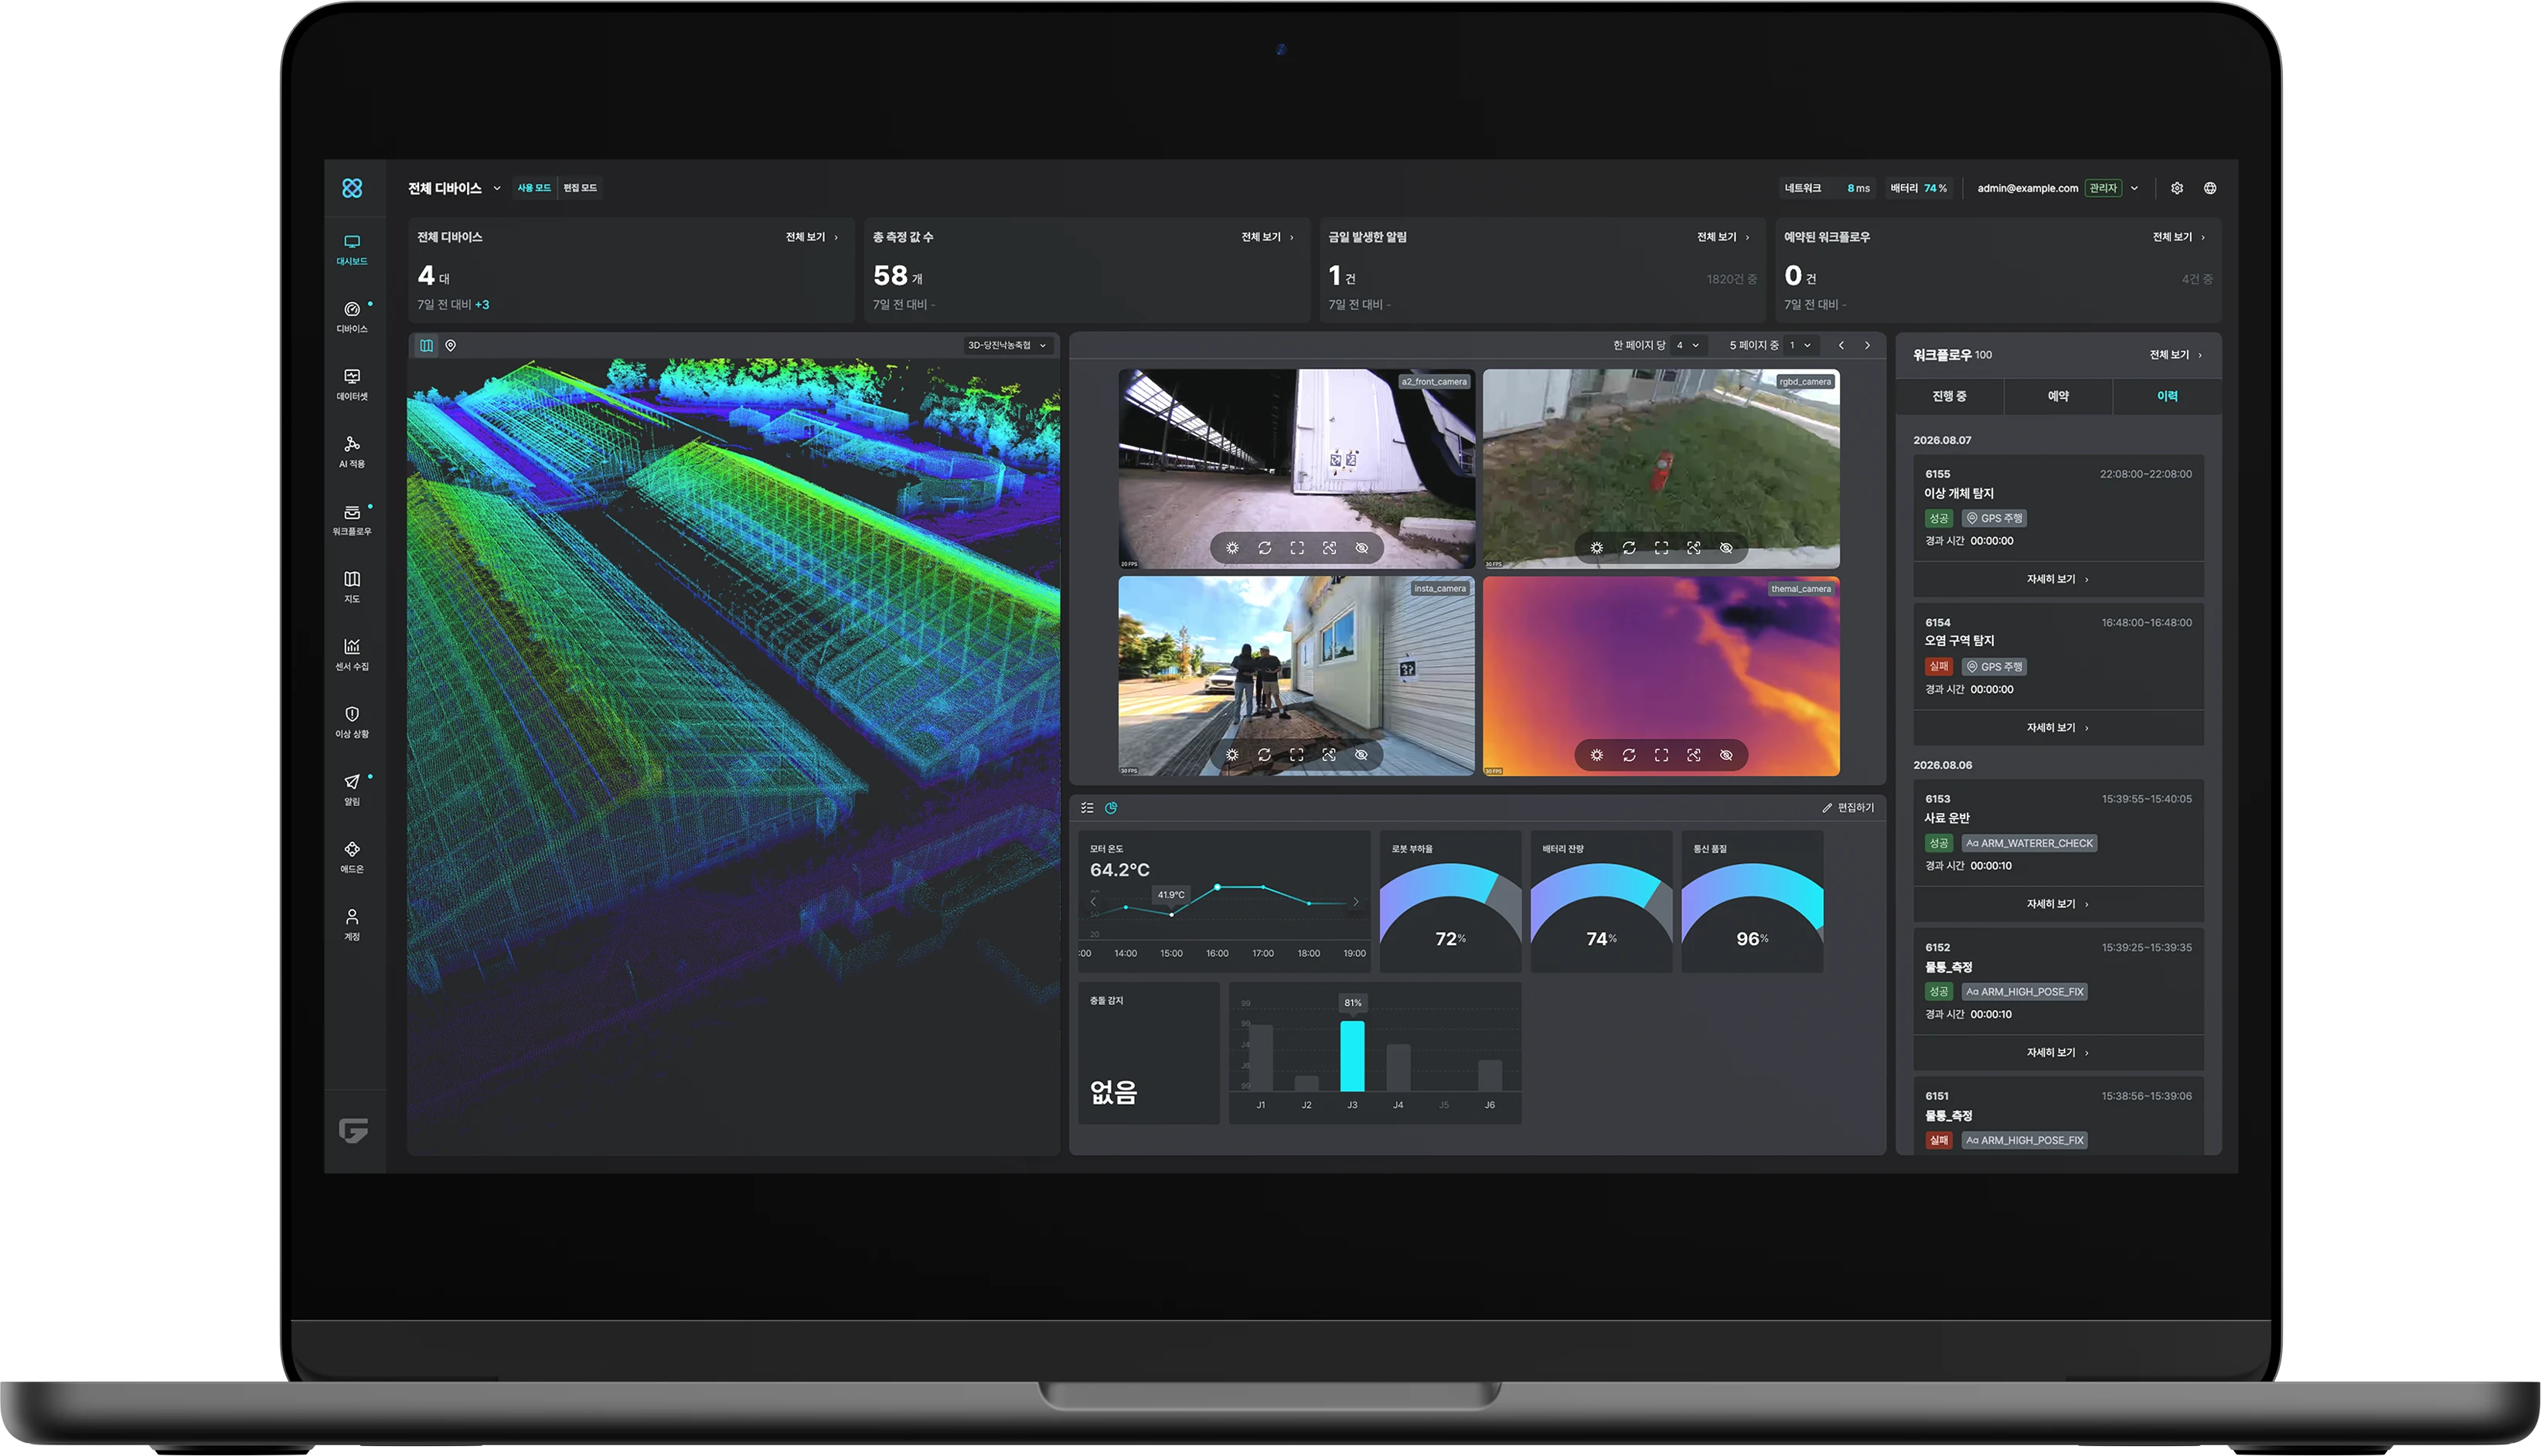
TeamGRIT implemented a system based on the robot integrated management solution CoBiz, connecting the ship GPS receiver and quadruped robot Go2-X, enabling integrated monitoring of GPS data alongside robot operational information.
A mounting structure, power, and communication environment were configured to install the ship GPS receiver KGP-922 on the robot, and GPS reception data was linked to CoBiz through the robot's onboard PC. Separate GPS equipment KGC-300 was also tested for reception and integration.
The system processes NMEA data output from the GPS receiver to display location, time, speed, heading, and satellite reception status, allowing joint viewing with the robot's IMU, odometry data, and onsite video. Notably, it compares the GPS location and movement data with robot movement data from IMU and odometry to analyze sensor discrepancies, which are used to determine GPS anomalies.
Additionally, alert functions for anomalies such as sudden location changes and time inconsistencies were implemented, alongside log saving capabilities segmented by test sections. A dedicated software simulator was employed to reproduce various GPS anomaly scenarios and to iteratively verify data changes and alert operations.